|
Yechen Fan 「樊晔陈」 I am a master's student at the School of Mechanical Engineering and Automation, Fuzhou University, and I expect to graduate in June 2027. My research is conducted at the Fujian Provincial Key Laboratory of Special Intelligent Equipment Safety Measurement and Control, where I am advised by Associate Professor Jinhua Ye and Lab Director Gengfeng Zheng. I also collaborate with Professor Haibin Wu at Fuzhou University and Associate Professor Huixin He from the School of Computer Science and Technology, Huaqiao University. I received my bachelor's degree in Mechanical Design, Manufacturing and Automation in June 2024. My research focuses on robot learning for manipulation, with a particular interest in multimodal imitation learning, bimanual manipulation, and real-world robot deployment. I aim to develop learning-based methods that enable robots to perform robust and generalizable manipulation from limited demonstrations and heterogeneous data sources, such as simulation, teleoperation, and human videos. Previously, I also worked on physical human-robot interaction (pHRI), including collision detection and compliant control for collaborative robots. Currently, I am working toward becoming a full-stack robotics engineer. |
|
Publications |
|
Hemispheric Diffusion: A Compositional Generative Policy for Coordinated Bimanual Manipulation
Yechen Fan, Jinhua Ye, Xianyou Ji, Chenyang Song, Haibin Wu, Gengfeng Zheng and Jiafu Wan Under Review project page / paper / video / code |
|
|
BimanualShift: Arm-Conditioned Residual Skill Transfer from Unimanual Policies to Bimanual Manipulation
Yechen Fan, Jinhua Ye, Xianyou Ji, Chenyang Song, Haibin Wu, Gengfeng Zheng and Jiafu Wan Under Review project page / paper / video / code |
|
|
Tool-Action Comprehension: A Cross-Morphology Imitation Learning Framework for Bimanual Manipulation
Yechen Fan, Xinjie Zhang, Jianghao Zhao, Xiaohan Liu, Haibin Wu, Jinhua Ye and Gengfeng Zheng IEEE/ASME Transactions on Mechatronics (T-MECH), (JCR: Q1, IF: 6.3), 2026 project page / paper / video / code |
|
|
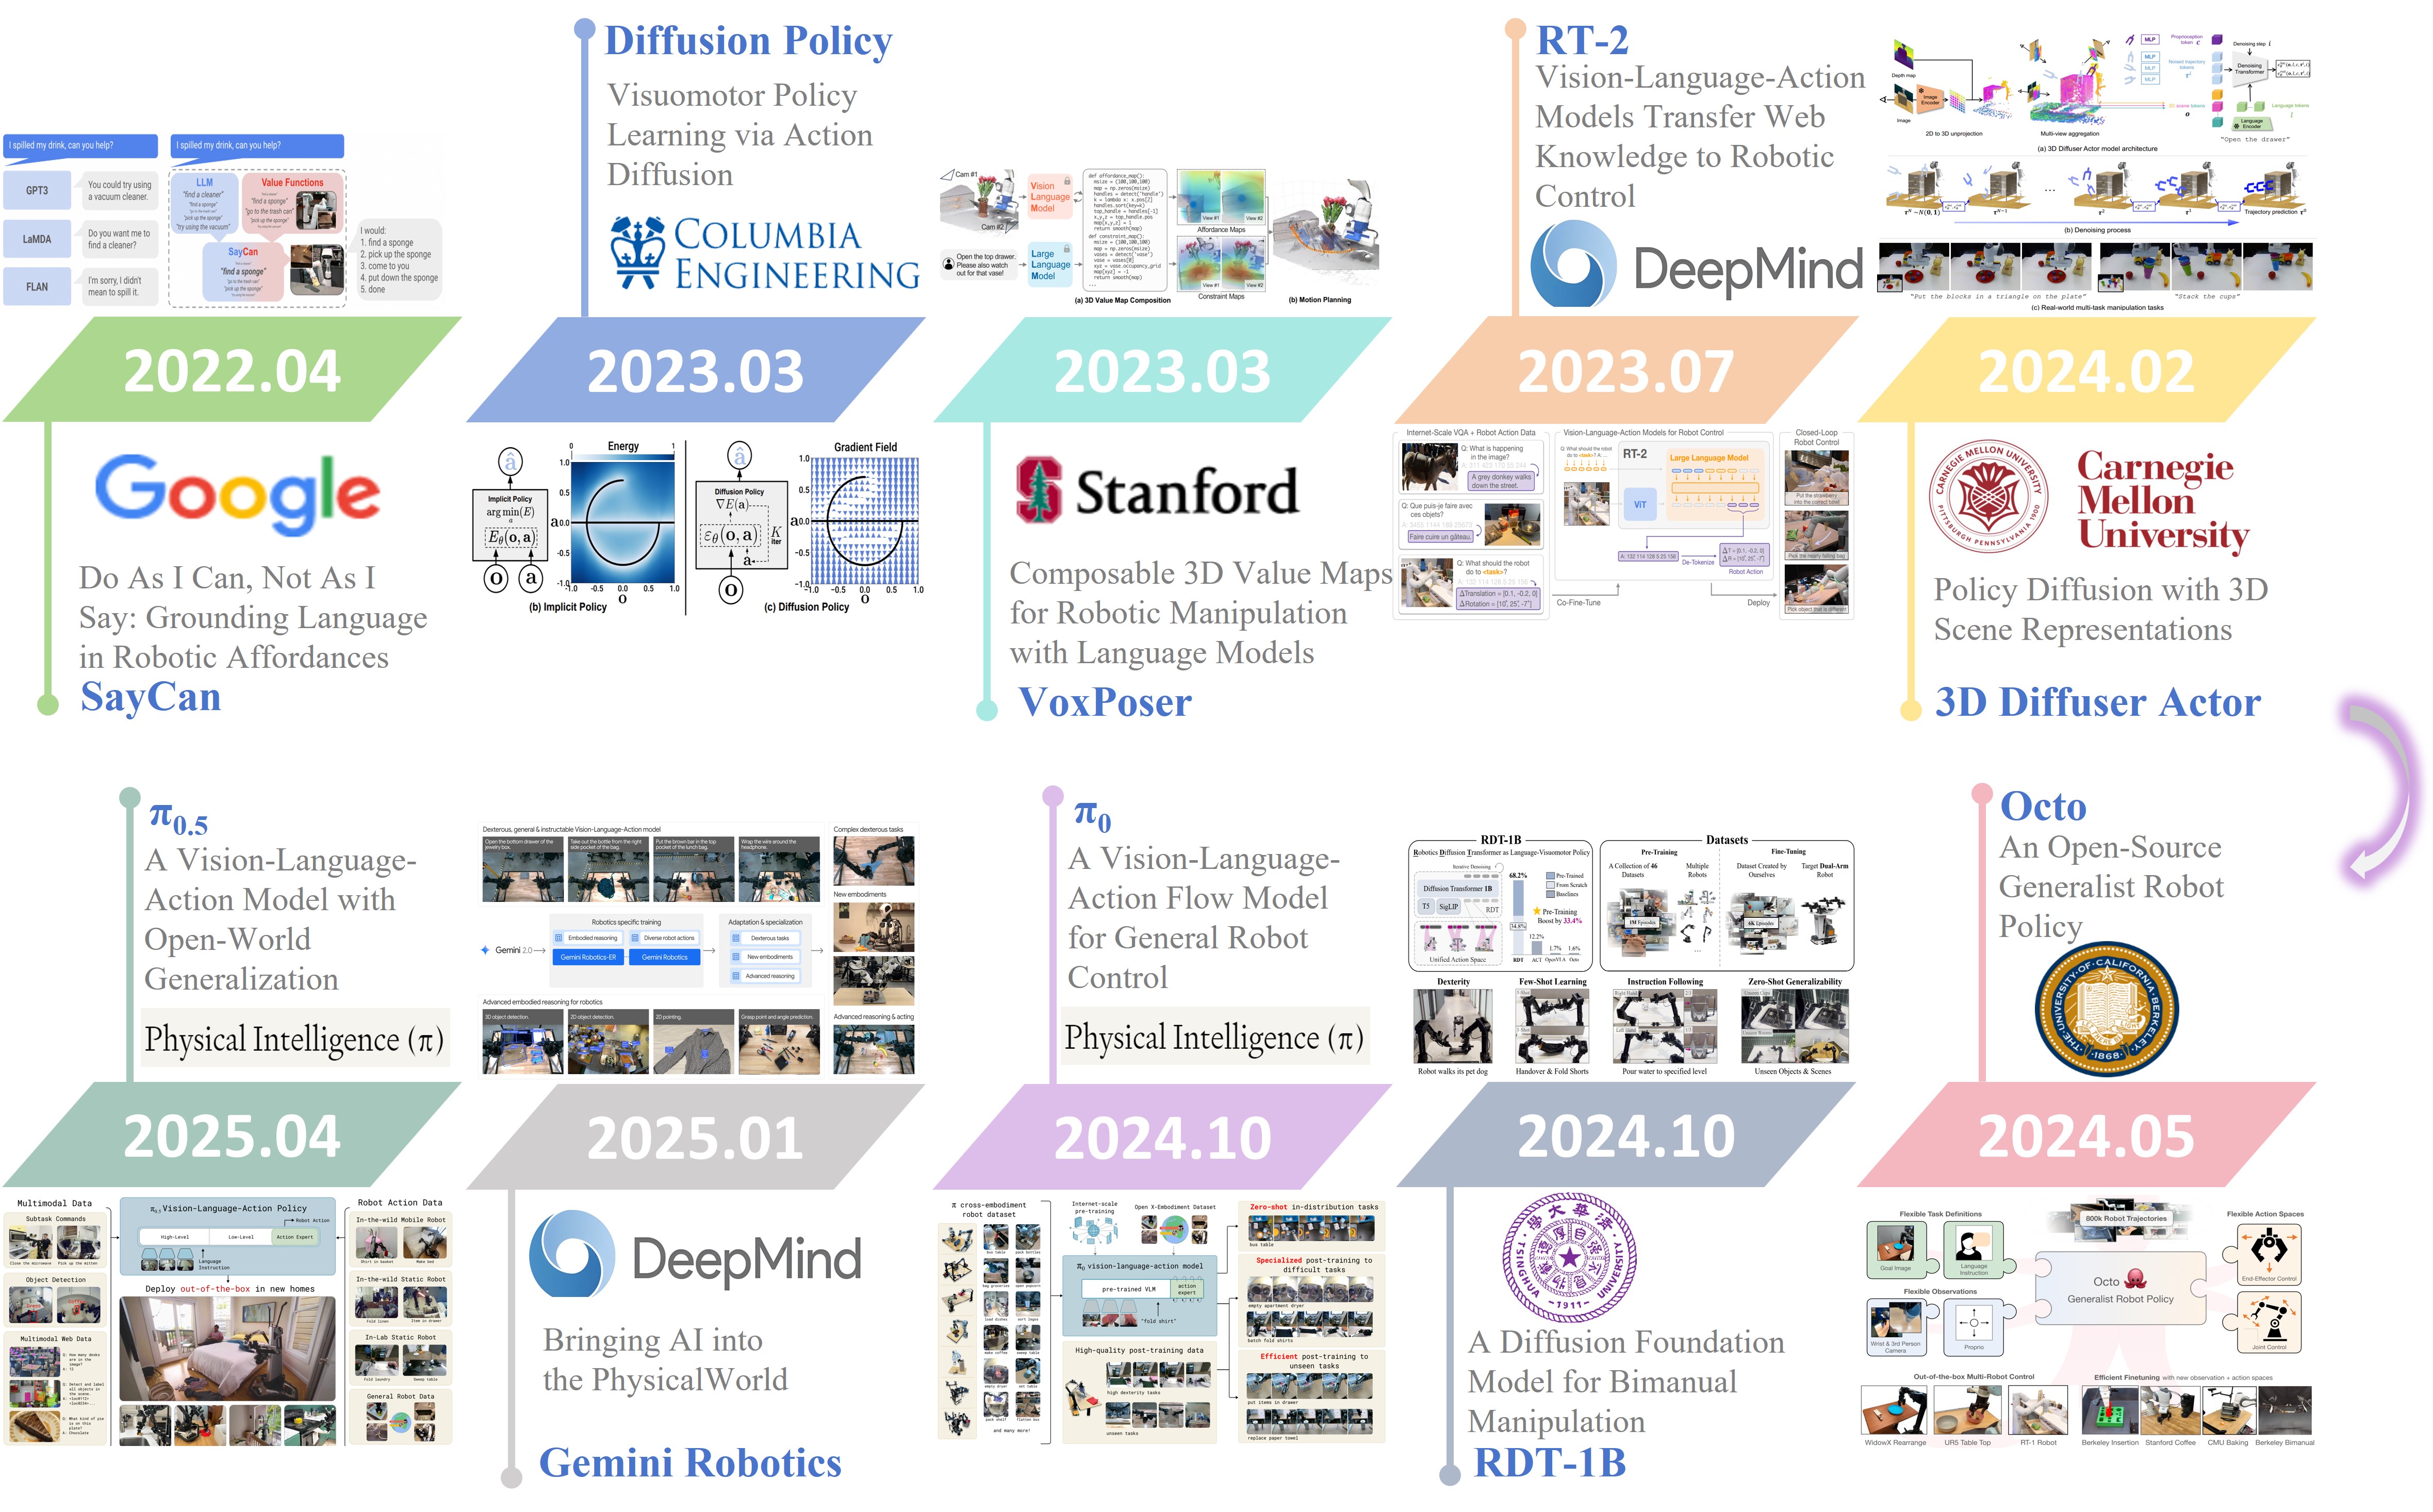
Towards Industry 5.0: Emerging Trends in Dual-Arm Human-Robot Collaboration
Jinhua Ye, Yechen Fan, Gengfeng Zheng, Houde Dai, Chenyang Song, Haibin Wu and Yu Zhang Biomimetic Intelligence and Robotics, (JCR: Q1, IF: 5.4), 2026 paper |
|
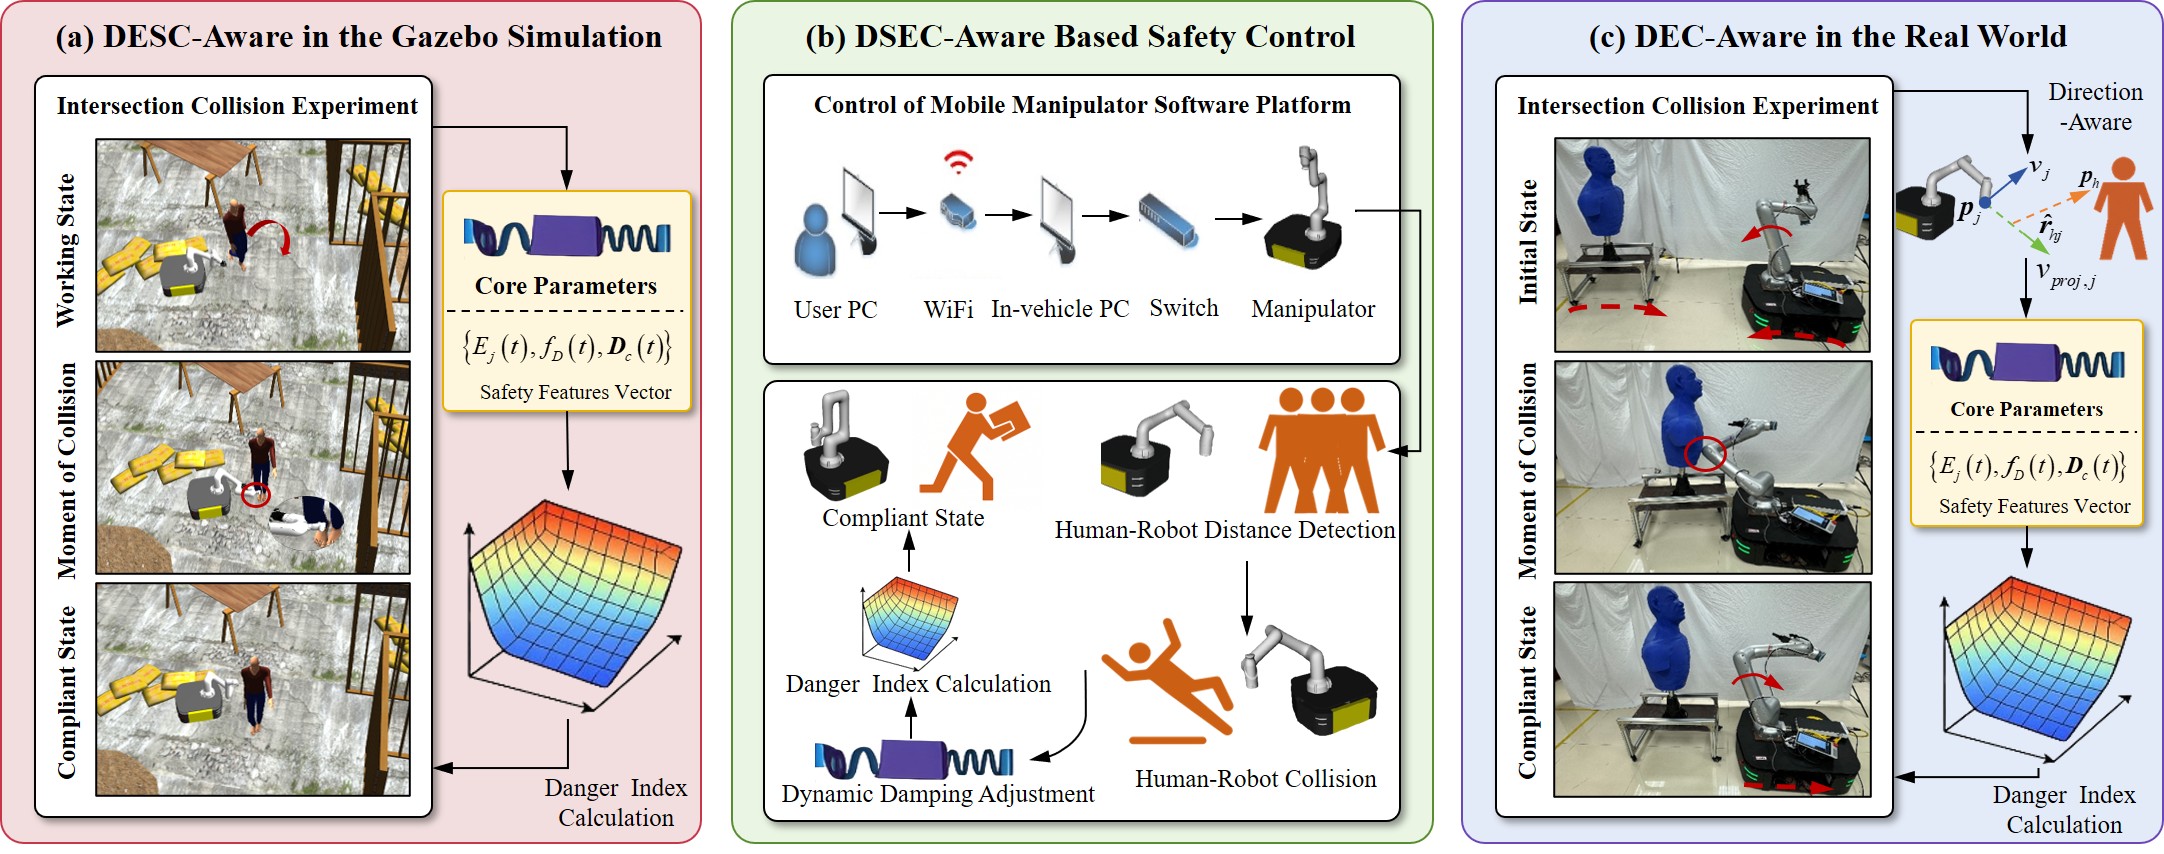
DSEC-Aware: Post-Collision Safety Control of Mobile Manipulators via Directional Energy Constraints
Jinhua Ye, Yechen Fan, Linxin Hong, Haibin Wu and Gengfeng Zheng IEEE Robotics and Automation Letters (RA-L), (JCR: Q1, IF: 5.3), 2025 paper |
|
A Bayesian Framework Based on Gaussian Mixture Model and Hidden Markov Process for Collision Detection in Cobots
Jinhua Ye, Yechen Fan, Haibin Wu, Xin Zhang, Jianghao Zhao, Xinjie Zhang and Gengfeng Zheng IEEE Robotics and Automation Letters (RA-L), (JCR: Q1, IF: 5.3), 2025 paper / video |
Projects |
|
UR5e-LeRobot
A LeRobot-based UR5e deployment framework that inherits LeRobot policy pipelines and extends them to real-world single-arm and bimanual robot learning, supporting SpaceMouse, Quest 3 VR, Gello, and keyboard teleoperation. code |
|
|
UR5e-DP-Family
A real-world UR5e deployment framework for DP, DP-R3M, DP3, DP3-Official, and iDP3, covering both 2D image-based and 3D point-cloud-based policies for single-arm and bimanual manipulation. code |
|
|
UR5e-Grasp
A complete UR5e RGB-D grasping system that integrates YOLO/OBB and GraspNet-based grasp estimation for autonomous tabletop object grasping. code |
|
|
SafeCarryCBF
Safe mobile bimanual manipulation with flow matching policy and predictive whole-body control barrier functions. code |
Services |
|
The website is borrowed from Jon Barron. |